Robot perception · Python / PyTorch / OpenCV
Webots Neural Vision Robot
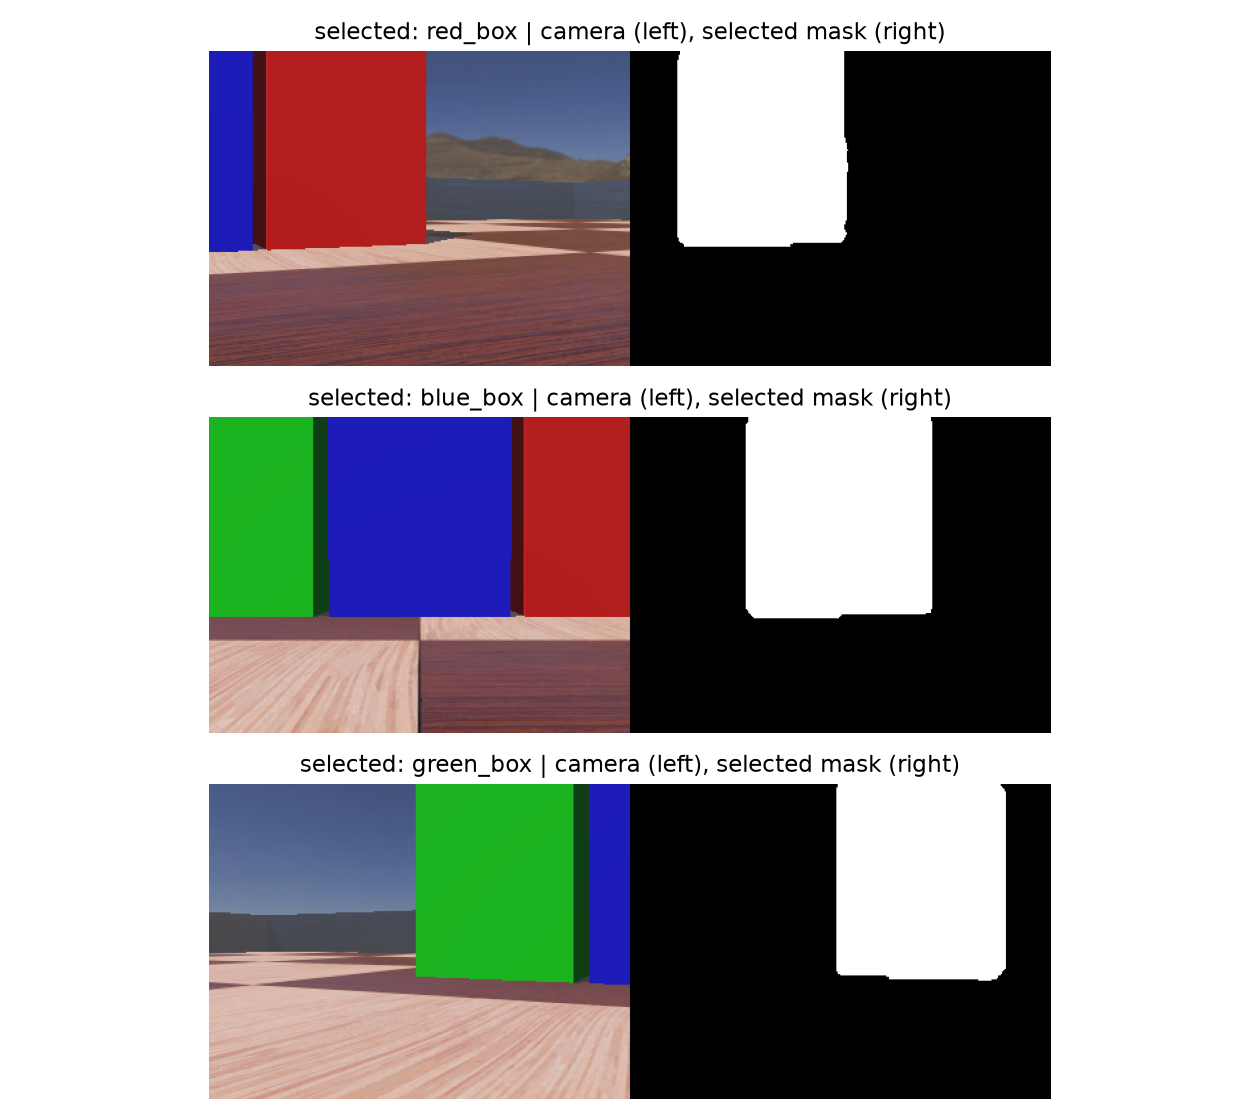
A small e-puck robot that finds a selected color, turns toward it, and stops as it approaches.
I compared a 1,460-parameter CNN with an HSV baseline using 3,600 fresh synthetic images and 108 paired robot trials. Both methods use the same steering and stopping controller.
Evaluated in simulation; physical hardware has not been tested.